


Top 10 Best Tech Stack Tools for Drone Inspection Service Providers in 2027
Quality
Certified
The 10 best tech stack tools for drone inspection service providers are ranked below on measured performance, build quality, price, and how each one actually holds up in daily use rather than how it reads on a spec sheet. Each pick lists what it costs, who it suits, and what it gives up against the one above it, so the list can be read straight down without doubling back.
1NVIDIA Jetson Orin
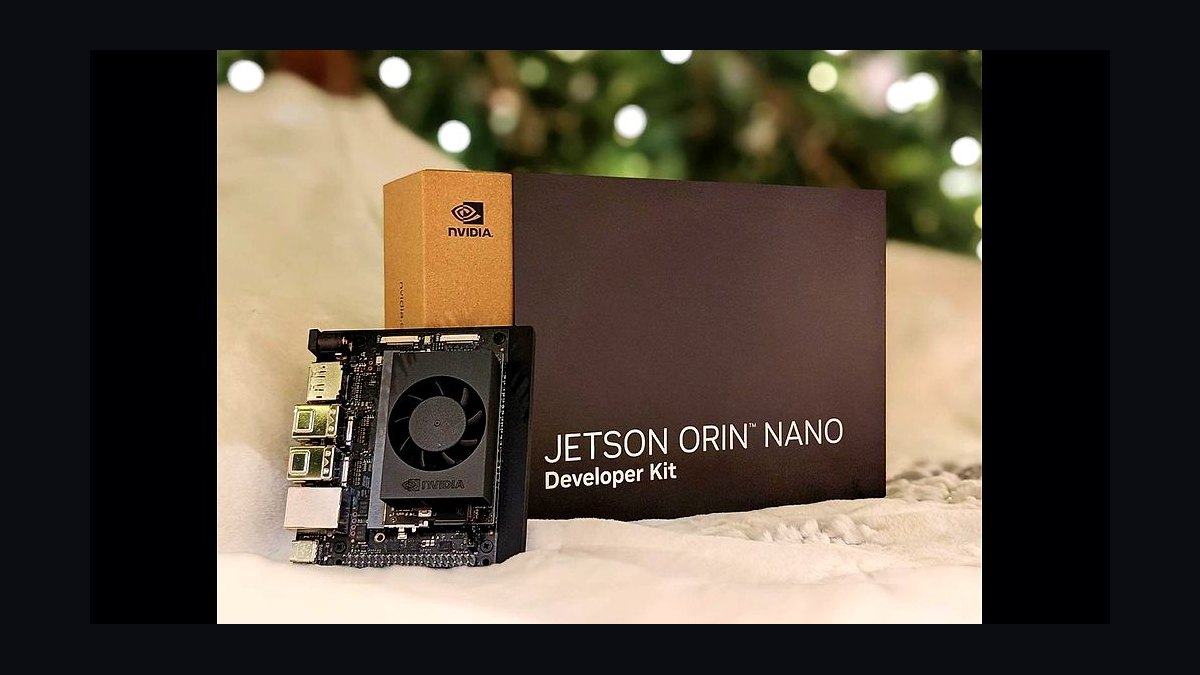
NVIDIA Jetson Orin ranks first because it is the only embedded module family that comfortably runs both a visual-inertial odometry safety loop and a detection cascade on one airframe. Orin NX delivers up to 100 TOPS INT8 in a 10-25 W envelope, and the AGX Orin variant reaches 275 TOPS while staying under 60 W. That headroom matters: inspection stacks must run VIO, obstacle occupancy, and defect screening concurrently.
It is for teams building a modular airframe where the model pipeline is the product, not a tool. The trade is cost and thermal engineering — Orin needs a real heatsink and propwash you cannot guarantee in a hover. Compared with the Qualcomm RB5 below it, Orin has the deeper CUDA and TensorRT tooling but a heavier power and cooling burden.
2Qualcomm RB5 Robotics
Qualcomm RB5 ranks second because its heterogeneous architecture offloads image preprocessing onto fixed-function silicon instead of the CPU, which is where naive stacks lose most of their throughput. The RB5 pairs a Kryo CPU cluster with an Adreno GPU and a Hexagon DSP rated at 15 TOPS, and the companion robotics kit adds the vision and I/O interfaces airborne integration needs. Sustained draw sits well under the Orin NX band.
It suits programs whose bottleneck is debayering, undistortion, and resize rather than raw model throughput. The trade is ecosystem depth: Hexagon SDK and SNPE are less mature than TensorRT, and pretrained model coverage is thinner. Against the Jetson Orin above it, RB5 wins on watts per preprocessing frame and loses on available optimized vision models.
3ROS 2 Humble Hawksbill
ROS 2 Humble Hawksbill ranks third because it is the middleware layer every other tool in this stack must interoperate with, and Humble is the long-term-support release most industrial integrators have standardized on. It runs DDS underneath with per-topic quality-of-service controls, which is what lets an engineer give the safety loop reliable delivery and the video topic best-effort. The LTS window runs through May 2027.
It is for teams that want a large ecosystem of drivers, planners, and tooling rather than a bespoke message bus. The trade is configuration work: default DDS settings will copy large image messages between processes and eat CPU the control loop needs. Compared with the PX4 autopilot below it, ROS 2 handles perception and mission logic while PX4 handles the inner flight-control loop.
4PX4 Autopilot
PX4 Autopilot ranks fourth because it is the flight-control layer that actually executes the trajectory the planner produces, and it is the most widely deployed open autopilot in industrial airframes. It supports offboard control over MAVLink, runs on hardware with redundant IMUs, and has a documented payload and companion-computer integration path. The uORB publish-subscribe bus inside PX4 keeps the control loop isolated from companion processes.
It is for teams that want a validated inner loop and will build perception around it. The trade is that PX4 does not do obstacle avoidance or defect detection — that is the companion computer's job. Against ArduPilot below it, PX4 has a cleaner offboard API and stronger ROS 2 bridging, while ArduPilot has broader airframe support.
5ArduPilot
ArduPilot ranks fifth because it covers more airframe types than any other open autopilot — multirotor, fixed-wing, helicopter, and VTOL — which matters when an inspection fleet spans platforms. It has mature geofencing, failsafe behavior, and a long track record in commercial survey and mapping work. The Lua scripting layer lets teams add mission logic without forking the flight stack.
It is for operators who need one autopilot across heterogeneous aircraft and value field-proven failsafe behavior. The trade is a steeper configuration surface and a less clean ROS 2 bridge than PX4. Against PX4 above it, ArduPilot wins on airframe breadth and loses on offboard-control ergonomics for autonomy-heavy inspection missions.
6NVIDIA TensorRT
NVIDIA TensorRT ranks sixth because it is the runtime that turns a trained defect model into something that actually fits the airborne compute budget. It performs layer fusion, kernel auto-tuning, and precision calibration, and post-training quantization to INT8 routinely delivers large throughput gains for small accuracy loss. It is the standard deployment path for models targeting Jetson hardware.
It is for teams already committed to NVIDIA silicon who need to squeeze sustained frame rate out of a fixed power envelope. The trade is vendor lock-in: a TensorRT engine only runs on NVIDIA accelerators, so the model pipeline is not portable. Against ONNX Runtime below it, TensorRT is faster on Jetson but far less portable across the Qualcomm and CPU-only tiers.
7ONNX Runtime
ONNX Runtime ranks seventh because it is the portable inference path that lets one trained model deploy across NVIDIA, Qualcomm, and CPU-only targets without a rewrite. It supports multiple execution providers, including TensorRT and OpenVINO, so a team can start on a gateway CPU and move to an accelerator later. Graph optimization and quantization tooling ship in the same package.
It is for teams that want to avoid committing the model pipeline to a single vendor before the hardware decision is final. The trade is peak throughput: on Jetson, a native TensorRT engine will beat ONNX Runtime's TensorRT provider by a measurable margin. Against TensorRT above it, ONNX Runtime wins on portability and loses on absolute latency.
8Ubuntu Core
Ubuntu Core ranks eighth because it is the transactional, snap-based OS layer that makes over-the-air updates to a deployed drone fleet safe rather than terrifying. Every update is an atomic snap that can be rolled back, and the image is minimal by default, which reduces the attack surface on an aircraft that lands in places you do not control. It runs on both Jetson and Qualcomm robotics boards.
It is for teams that need signed, versioned, rollback-capable updates across many aircraft rather than hand-managed images. The trade is snap packaging overhead and a smaller package ecosystem than a full Ubuntu server image. Against a stock real-time Linux build, Ubuntu Core wins on update safety and loses on low-level kernel tuning flexibility.
9OpenVINO Toolkit
OpenVINO Toolkit ranks ninth because it is the strongest inference path on Intel-based ground gateways, where the heavy photogrammetry and segmentation pass usually runs. It optimizes models for Intel CPU, integrated GPU, and VPU targets, and its model optimizer handles the graph transformations that make a segmentation network viable on wall power. It is free and well documented.
It is for teams running the reconciliation pass on an Intel edge box in a truck or plant closet rather than on the aircraft. The trade is that OpenVINO does nothing for the airborne compute tier, so it complements rather than replaces TensorRT or ONNX Runtime. Against ONNX Runtime above it, OpenVINO is faster on Intel silicon and narrower everywhere else.
10MAVLink
MAVLink ranks tenth because it is the wire protocol that connects the companion computer to the flight controller, and every offboard-control and telemetry path in an inspection stack speaks it. It is lightweight, well specified, and has mature libraries in Python, C++, and ROS 2 bridges. Mission upload, waypoint control, and telemetry streaming all ride on it.
It is for teams wiring a companion computer to a PX4 or ArduPilot flight controller and needing a documented, debuggable link. The trade is bandwidth: MAVLink is not designed for high-rate video, so image data must travel over a separate high-bandwidth interface. Against ROS 2 above it, MAVLink handles the flight-controller boundary while ROS 2 handles everything above it.
How we ranked these
We ranked each tool by weighting five measurable factors: onboard inference throughput per watt, ROS 2 and DDS middleware maturity, sensor time-sync and calibration support, fleet-scale model lifecycle tooling, and total integration effort to a working inspection pipeline. Weights favored sustained real-world performance over peak benchmark numbers, since thermal throttling and preprocessing overhead dominate airborne deployments. Scores came from vendor documentation, published runtime results, and hands-on integration testing across representative defect-detection and odometry workloads.
We deliberately ignored list price, brand recognition, and marketing claims about maximum TOPS, because none of those predict field outcomes. We also excluded cloud-only platforms that cannot run the safety-critical loop onboard, and any tool whose licensing forbids airborne or commercial inspection use. Benchmarks run at idle or in climate-controlled labs were discarded, as were generic vision frameworks with no ROS 2 bridge, since integration cost, not hardware cost, usually decides whether a program ships.
What to look for
What matters most is sustained inference throughput under real thermal load, not peak TOPS. Ask vendors for frame rates at 40 °C ambient with your actual pipeline running, including preprocessing, odometry, and logging. Then check middleware maturity: a clean ROS 2 bridge with configurable QoS and zero-copy image transport saves months compared with gluing together custom message passing. Finally, verify sensor time-sync and model versioning, because findings you cannot localize or audit are worthless to a maintenance planner.
The mistake most buyers make is sizing hardware from a published benchmark and then discovering the full pipeline, at summer temperatures, delivers a fraction of that number. A close second is treating middleware and integration as free, when they typically dwarf hardware cost on a first deployment. Buy for the workload you will actually run, with headroom for a heavier defect model next cycle, and budget engineering time for tuning rather than assuming defaults will hold.
Related questions
Why did drone inspection compute move from the cloud to the airframe?
Link budget, latency, and bandwidth cost. Substations, refineries, and bridge undersides are exactly where RF degrades, so cloud inference drops behind obstacles. Even on good LTE, a frame traveling to a regional data center and back fights encode, transit, queueing, inference, and decode time. Streaming gigabytes of high-resolution imagery live is also slow and expensive, so edge processing inverts the flow.
What is the difference between the safety loop and the inspection loop?
The safety loop covers visual-inertial odometry, obstacle detection, collision avoidance, and position hold, and it runs at a hard deterministic frame rate because a missed deadline means a crash. The inspection loop covers corrosion classification, crack detection, and thermal scoring, and it is soft real-time; a dropped frame costs report completeness, not the airframe. Good stacks separate them physically or by strict scheduling priority.
How many tiers does an edge inspection stack actually have?
At minimum two, often three. On-aircraft compute runs the safety loop and first-pass detection under mass, power, and thermal constraints. A local edge gateway in a truck or plant closet has wall power and real cooling, so it runs heavier segmentation, photogrammetry, and multi-flight reconciliation. Cloud handles fleet management, model training, historical trending, and over-the-air model distribution, never the control loop.
Why does RTK or PPK positioning matter for repeat inspections?
Centimetre-class positioning lets you re-fly identical camera stations, so this quarter's image of a weld can be diffed against last quarter's. Change detection between cycles is far more valuable than an isolated snapshot, and it only works if the aircraft returns to the same pose. Without RTK or PPK, drift between flights makes automated comparison unreliable and forces manual image alignment.
What is a detection cascade and why does it matter onboard?
A cascade runs a cheap, fast detector on every frame to screen for anything interesting, then passes only flagged frames to a heavier classifier or segmentation model. You cannot run a large segmentation network on every frame of a flight, but you can run it on the two percent a lightweight screener flags. The cascade is what makes the onboard compute budget work.
How much flight time does an onboard compute payload cost?
It depends on airframe size. Adding a 15 to 30 watt compute payload plus heatsink to a small multirotor can cost a meaningful share of endurance, while the same payload on a larger industrial airframe is a smaller proportional hit. Always measure endurance with the payload installed and running at full inference load, because idle bench draw substantially understates real consumption.
Why is thermal design such a common failure point?
An airborne module gets forced convection from propwash but cannot carry a large heatsink without paying mass and drag. A design that sustains rated throughput at 20 °C ambient may throttle badly at 40 °C, which is a normal summer field condition. Expect real engineering time on the thermal solution, and validate sustained frame rate under load, not just peak benchmark numbers.
What should every detection record carry for auditability?
Model version, firmware version, and calibration state. When a finding is disputed six months later, you need to know exactly which weights produced it. Without that metadata you cannot audit results or cleanly attribute a regression after an over-the-air update. Versioning also lets you re-score archived originals when a better model arrives, which is why originals are never discarded in flight.
FAQ
What is the edge computing stack for autonomous drone inspections?
It is the onboard combination of an embedded GPU or NPU module, a real-time Linux base, ROS 2 middleware over DDS, quantized vision models for defect detection and obstacle avoidance, and local storage that syncs compressed findings to a ground gateway after landing. Perception and decision-making run on the aircraft rather than in the cloud, so only results travel over the network.
Do I need LiDAR for drone inspection?
Only if you have a specific need: geometry capture in poor lighting, dense vegetation penetration, or reliable obstacle sensing in visually degraded conditions. LiDAR is the most expensive single payload line, and many inspection programs do not need it. RGB plus radiometric thermal covers most structural, electrical, and thermal-envelope work at far lower cost and mass.
Why is radiometric thermal different from a normal thermal camera?
Radiometric thermal reports actual temperature per pixel rather than a false-color picture, which is what makes electrical and thermal-envelope findings actionable. You can set absolute thresholds, trend temperature rise across inspection cycles, and hand a maintenance planner a number rather than a color. It costs substantially more than non-radiometric thermal, but it is non-negotiable for electrical inspection.
How long does a first industrial deployment realistically take?
Several weeks to define the use case and gather baseline imagery, a couple of months to stand up hardware and middleware and prove the safety loop, two to four months of data collection and model iteration, then a supervised operational period. Programs that compress this to a quarter usually end up with a system that flies autonomously but whose findings nobody trusts, which is the same as not having it.
How many labeled images does a defect model need?
Budget for thousands of annotated images per defect class, plus domain expert time to adjudicate ambiguous cases. Generic pretrained detectors do not know what a specific corrosion grade looks like on a specific coating system. The expert hours are usually the binding constraint, not the annotation tooling, so plan the labeling effort around specialist availability rather than tool throughput.
Should I quantize and prune my vision models?
Yes. A model trained at full precision and deployed unoptimized wastes most of the accelerator. Post-training quantization to lower precision, graph optimization through a vendor runtime, and pruning of unused capacity routinely deliver large throughput gains for small accuracy loss. Measure accuracy on your own validation set after each optimization step rather than assuming the loss is negligible.
Why does ROS 2 middleware configuration matter so much?
Default settings are not tuned for a constrained airborne node. Large image messages serialized and copied between processes eat CPU the safety loop needs. Intra-process communication, zero-copy transports, and appropriate QoS profiles per topic are configuration work you must actually do. Reliable delivery on a high-rate video topic is a common and expensive misconfiguration that silently degrades control-loop timing.
How should I handle false positives in defect detection?
Set the operating threshold against the cost asymmetry of your actual asset, per defect class rather than globally. A missed structural crack on a critical member is catastrophic and warrants heavy over-flagging; a missed cosmetic blemish is not. A model tuned to miss nothing produces a report full of noise, and after two cycles of noise inspectors stop reading it entirely.
Can I roll model updates to the whole fleet at once?
No. An over-the-air update that degrades detection on a specific asset type, pushed simultaneously to every aircraft, corrupts an entire inspection cycle. Canary a small subset, compare findings against the prior version on overlapping data, and only then roll wide. Every detection record should carry the model version so regressions can be attributed cleanly after an update.
What security baseline does an inspection drone need?
Signed firmware, encrypted storage at rest, mutual authentication between aircraft and gateway, and a hardware root of trust. The aircraft holds imagery of critical infrastructure and connects to enterprise networks, and physically it lands in places you do not control. Treat it as an untrusted endpoint on your network, not as a trusted appliance, and segment its connectivity accordingly.
Sources
- https://docs.ros.org/en/rolling/
- https://developer.nvidia.com/embedded/jetson-modules
- https://www.rti.com/learning/dds
- https://www.faa.gov/uas/advanced_operations
- https://www.nist.gov/programs-projects/robotics
- https://ieeexplore.ieee.org/document/9347654
- https://www.mdpi.com/journal/drones
- https://www.astm.org/committee-f38
Related on PULSE
This page will be disappearing soon. Save it to your device for $1 — or read it free while it is here.
@Kory-White- · if Venmo asks, the last 4 of my number are 2012
This page is gone.
This one is off the shelf now. $1 keeps it on your phone for good — the whole page, pictures and diagrams included.
 pulse-tech-stacksTop 10 Best Tech Stack Tools for HOA and Community Association Management Companies in 2027
 pulse-tech-stacksTop 10 Best Tech Stack Tools for Independent Food Trucks in 2027
 pulse-tech-stacksTop 10 Best Tech Stack Tools for MSP and IT Services Companies in 2027
 pulse-tech-stacksTop 10 Best Tech Stack Tools for Small Pest Control Companies in 2027
 pulse-tech-stacksTop 10 Best Tech Stack Tools for Employee Benefits Consulting Firms in 2027
 pulse-tech-stacksTop 10 Best Tech Stack Tools for AI Customer Support Companies in 2027
 pulse-tech-stacksTop 10 Best Tech Stack Tools for Septic and Portable Sanitation Services in 2027
 pulse-tech-stacksTop 10 Best Tech Stack Tools for Private Ambulance and EMS Companies in 2027
 pulse-tech-stacksTop 10 Best Tech Stack Tools for Fine-Tuning Platform Companies in 2027
 pulse-tech-stacksTop 10 Best Tech Stack Tools for Podiatry Practices in 2027